DAYS 1–2 FUNDAMENTALS · DAYS 3–5 ADVANCED
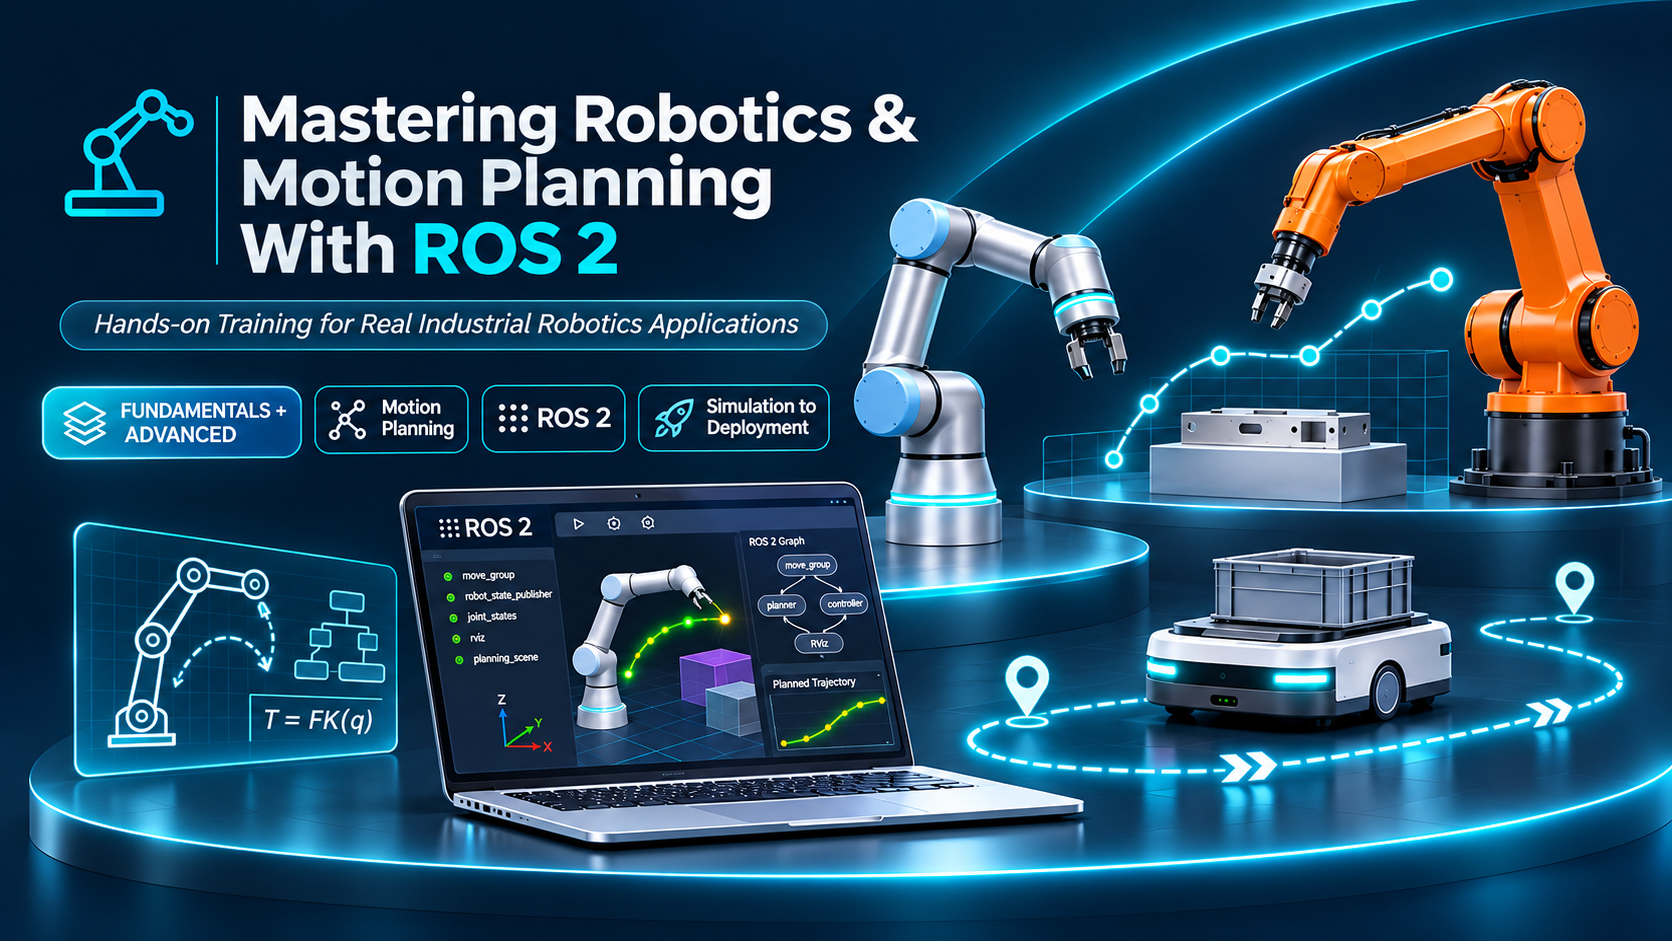
ROS 2 Robotics & Motion Planning
Learn ROS 2 fundamentals, robot modeling and motion planning, then apply them through simulated and real robot-arm exercises.
KEY MODULES
- ROS 2 nodes, topics, services and actions
- URDF, TF, RViz and robot kinematics
- MoveIt 2 motion planning and execution
View course outline
Fundamentals · Days 1–2
- Day 1 — ROS 2 setup, workspaces, packages, Git, nodes, topics, publishers and subscribers.
- Day 2 — Services, actions, parameters, rosbag2, launch files, RViz and robot descriptions.
- Day 3 — URDF/Xacro, TF2 transforms, robot joints, frames and forward kinematics.
- Day 4 — MoveIt 2 configuration, collision checking, planning groups, motion constraints and simulation.
- Day 5 — ROS 2 control, trajectory execution, pick-and-place workflow and integrated practical exercise.